|
Zhen Zhang | 张振 I'm currently a Ph.D. student in the Department of Mechanical and Automation Engineering, CUHK, under the supervision of Prof. Kwok Wai Samuel Au. I also work closely with Prof. Guoxin Fang. Before that, I was a research assistant at the MRC-CUHK. I received my M.Sc. degree in Electronic Engineering from CUHK. Previously, I obtained my B.Eng. degree with honours in 2021 from NWPU, Xi'an, China. Email / LinkedIn / Google Scholar / GitHub / |
|
News |
|
ResearchI'm interested in robotics, especially dexterous manipulation and robot learning. My current research focuses on dexterous manipulation with multi-fingered robotic hands. My previous research focused on 3D volumetric deformable object manipulation and quadruped robots. Representative works are highlighted. |
2026 |
|
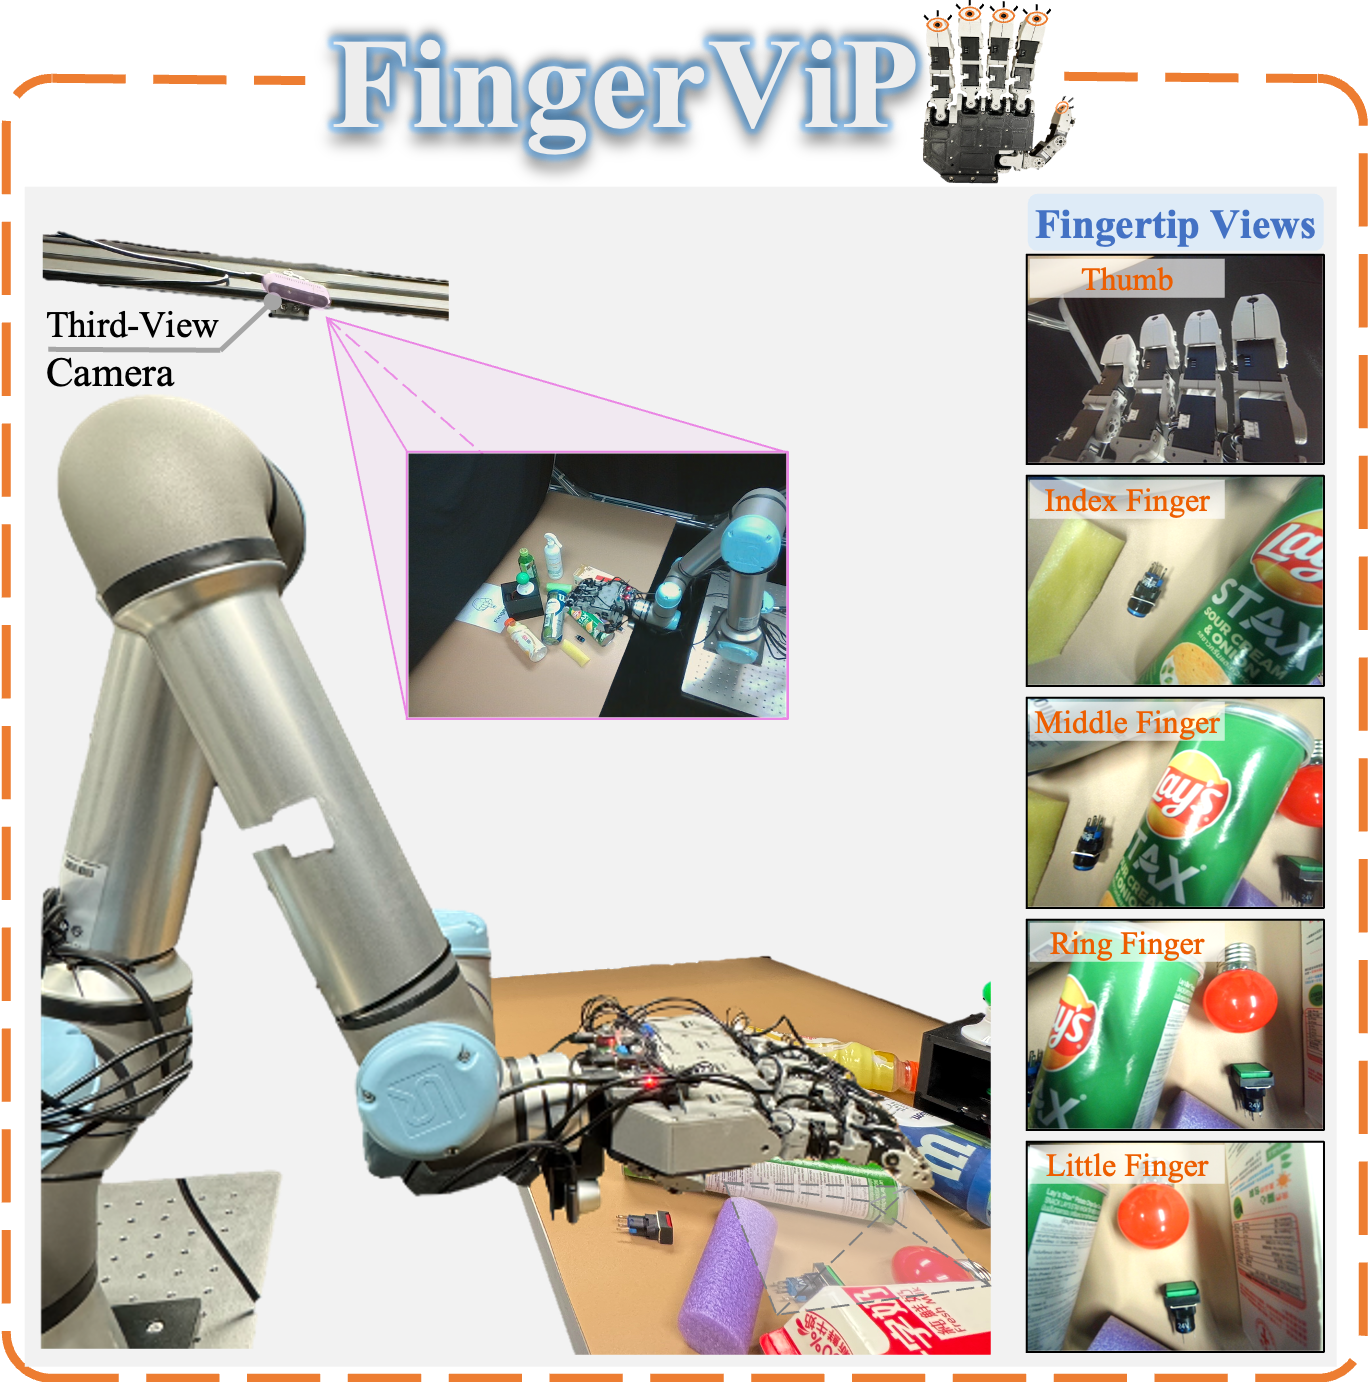
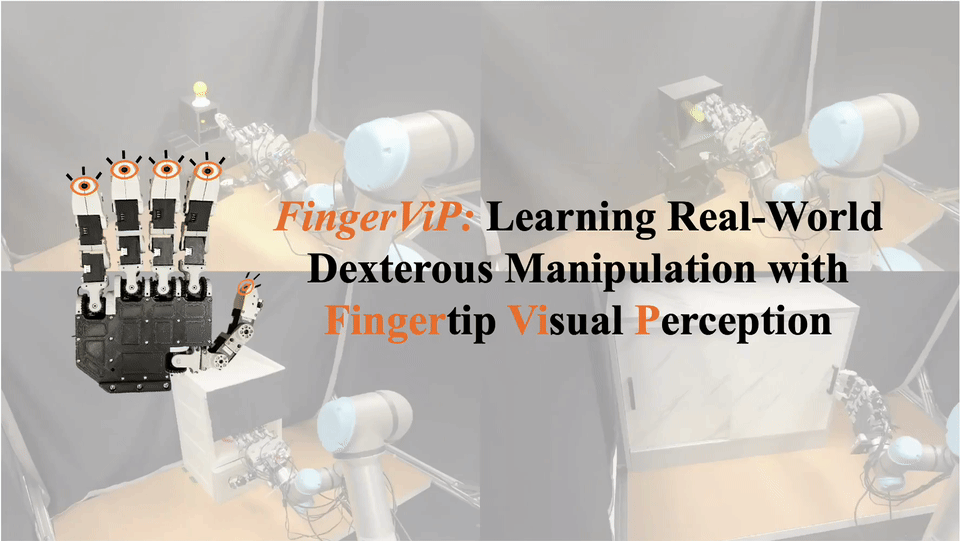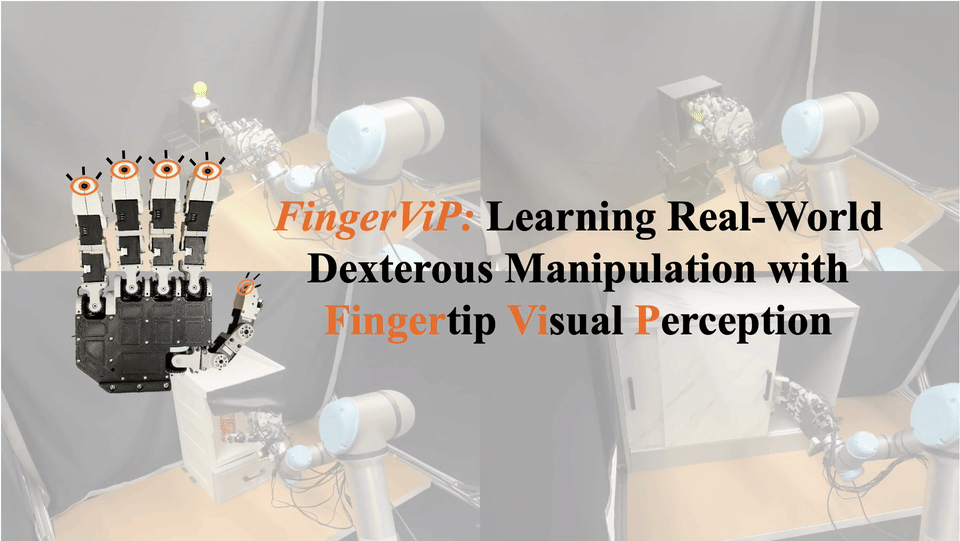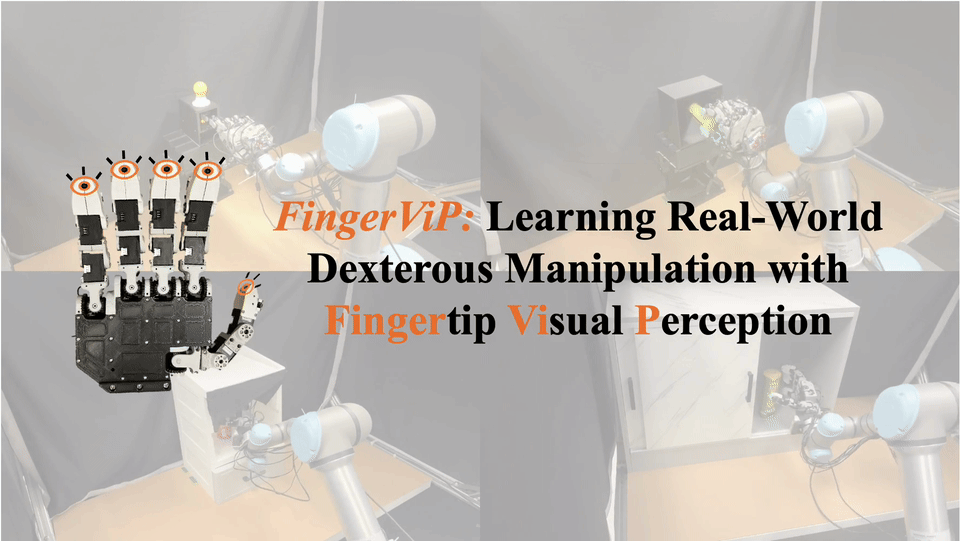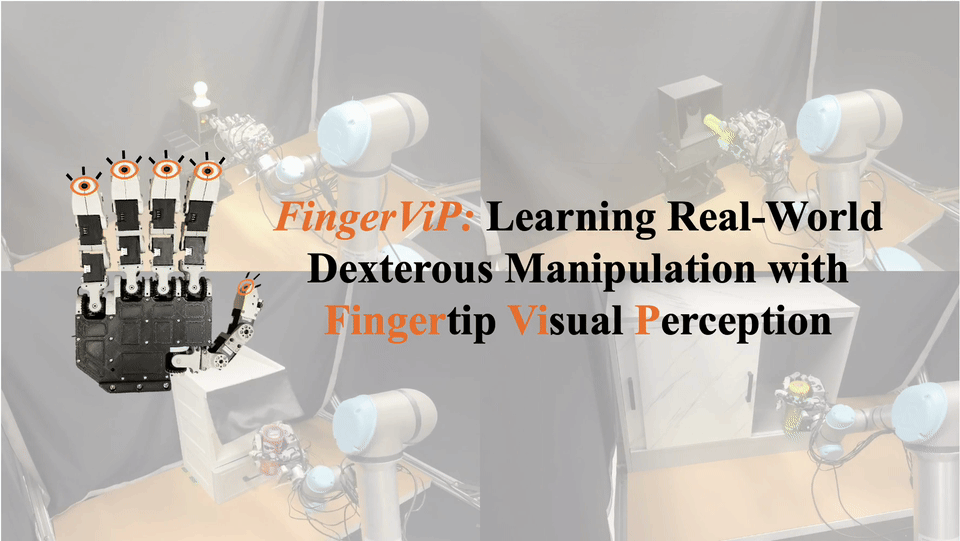
FingerViP: Learning Real-World Dexterous Manipulation with Fingertip Visual Perception
Zhen Zhang, Weinan Wang*, Hejia Sun*, Qingpeng Ding, Xiangyu Chu, Guoxin Fang, K. W. Samuel Au (* equal contribution) Project page / Code / arXiv / Conference on Robot Learning (CoRL), 2026 FingerViP integrates miniature cameras into robotic fingertips and learns a diffusion-based visuomotor policy from demonstrations, enabling dexterous manipulation with multi-view fingertip visual feedback. |
|
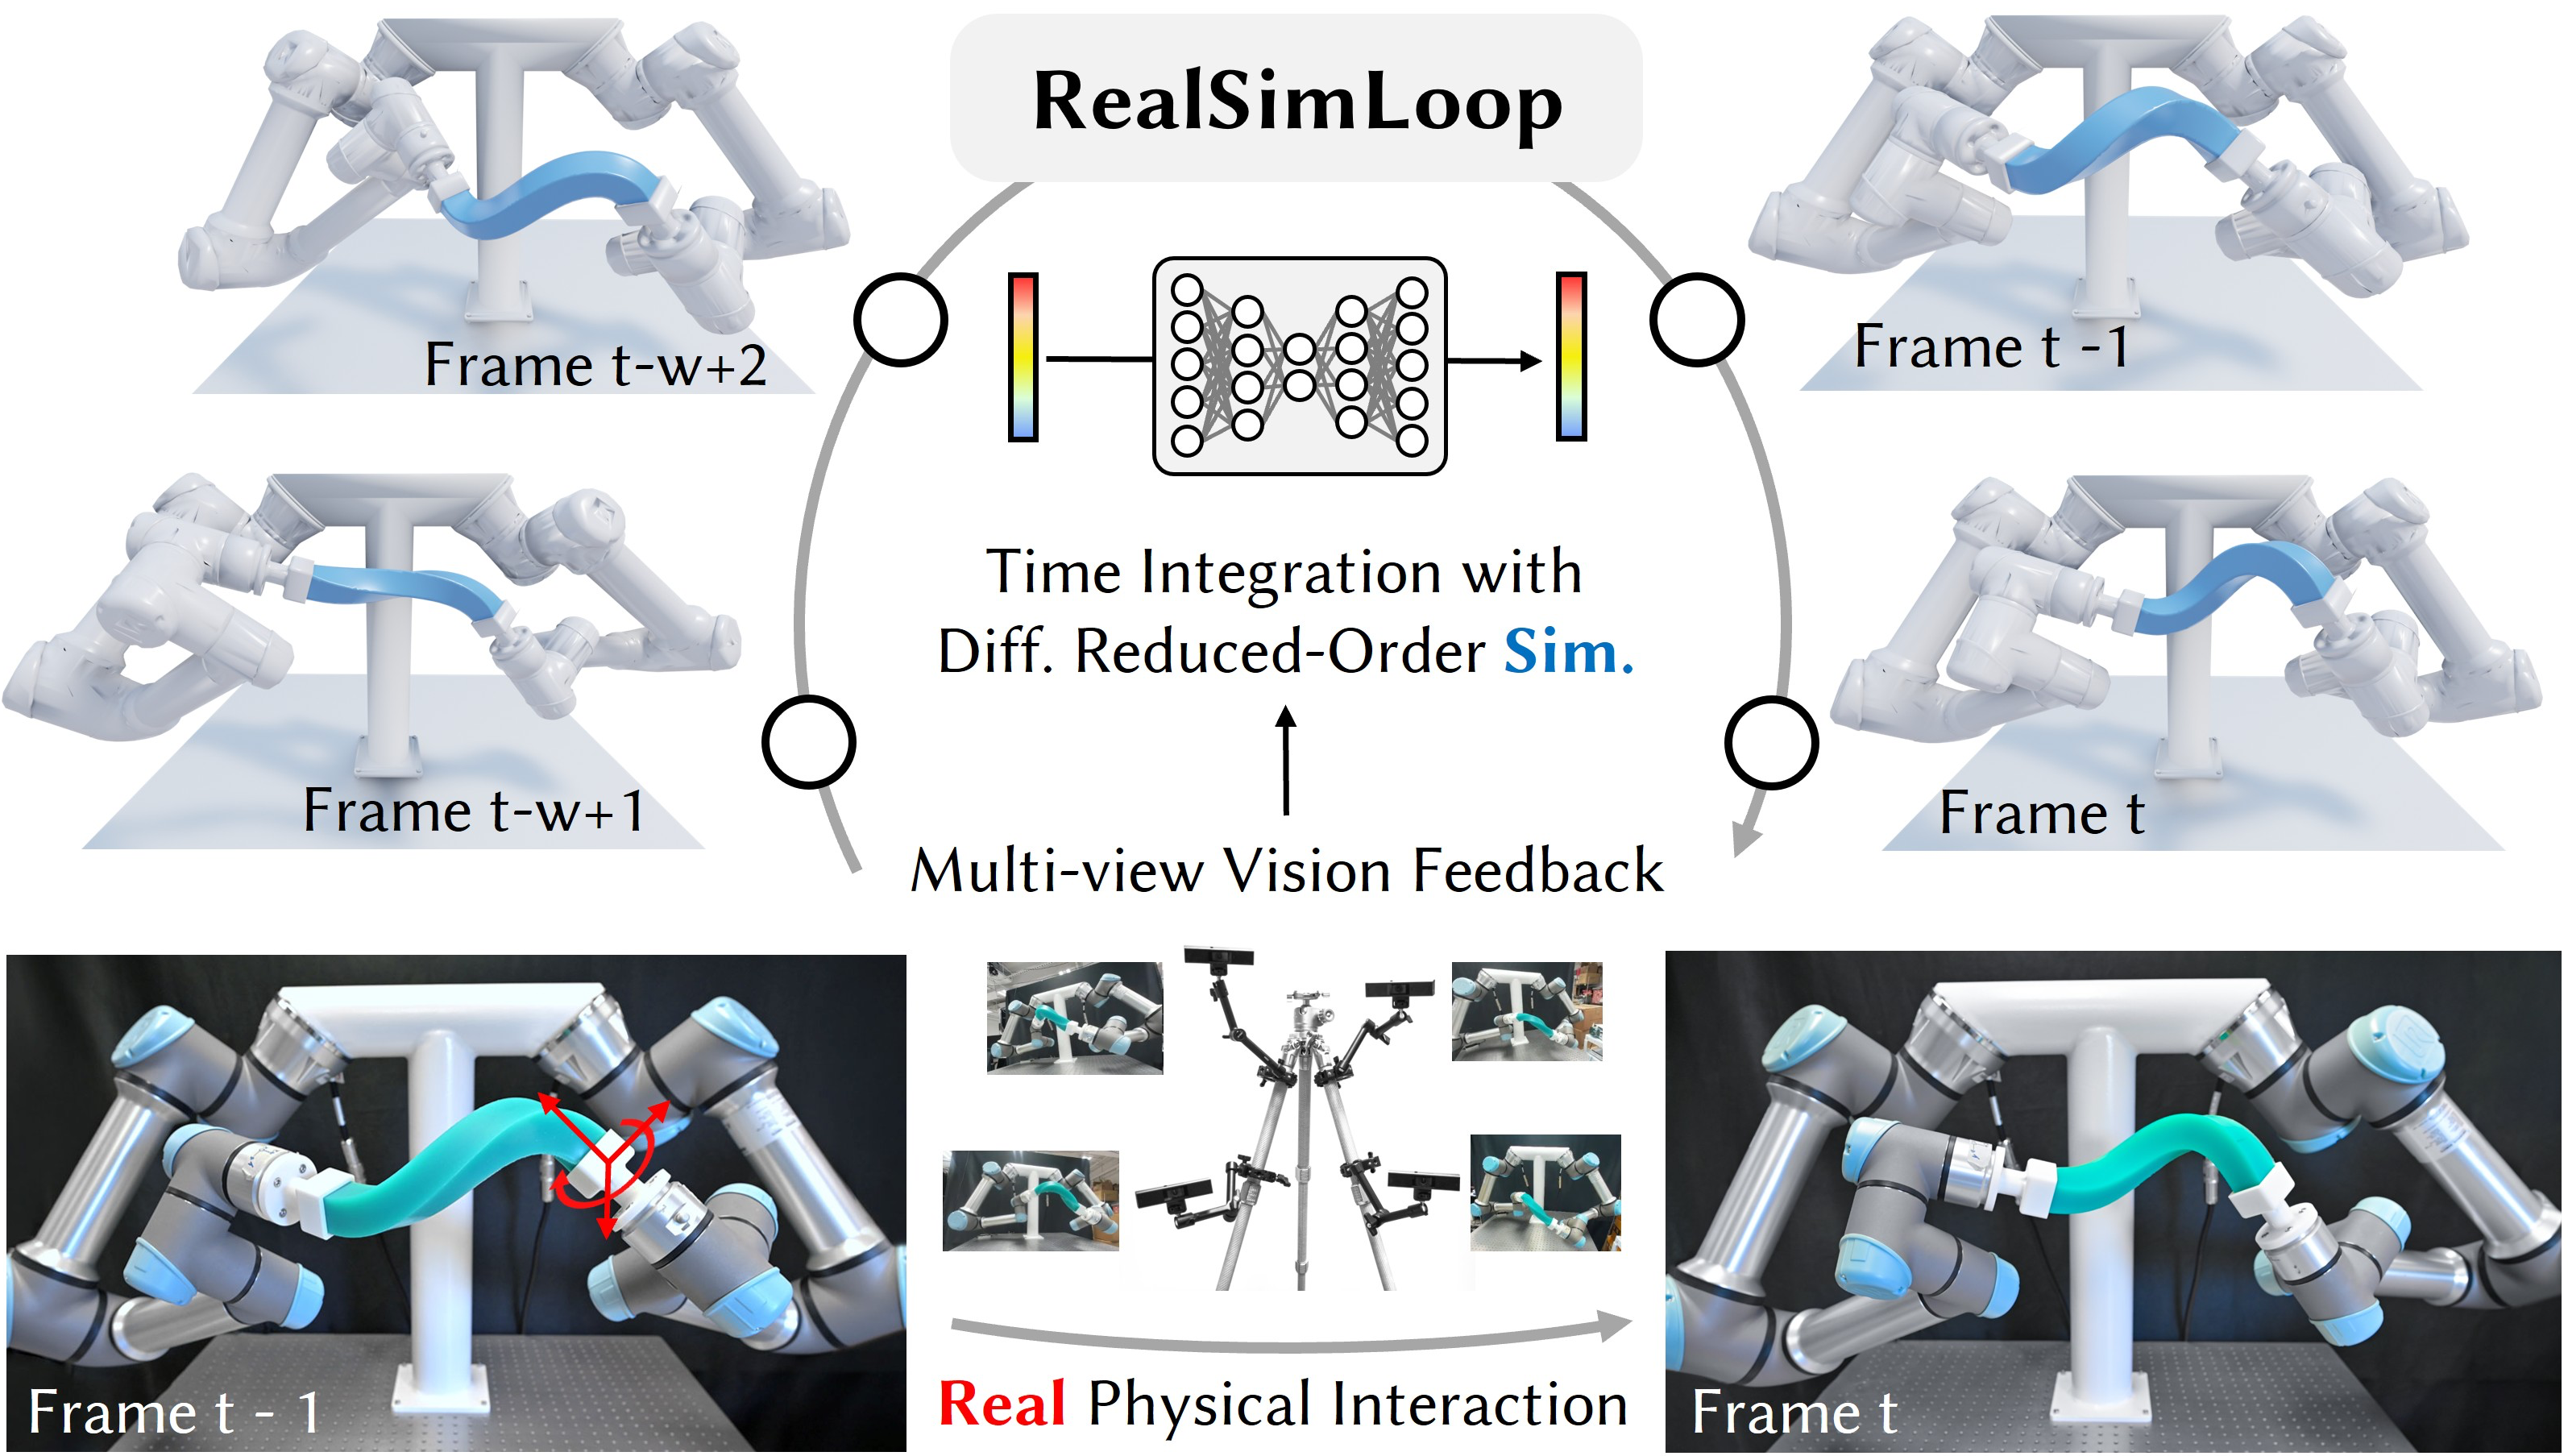
RealSimLoop: Online Real-to-Sim Adaptation via Differentiable Reduced-Order Simulation with Vision Feedback
Zhihao Cen, Chuhua Xian, Hailin Sun, Yuliang Liufu, Zhen Zhang, Xiangyu Chu, Hongmin Cai, Yunbo Zhang, Guoxin Fang Project page / arXiv / SIGGRAPH Asia 2026 RealSimLoop combines differentiable reduced-order simulation with 3D Gaussian Splatting to adapt physical parameters online from visual feedback, enabling external force prediction and 3D stress field reconstruction. |
2025 |
|
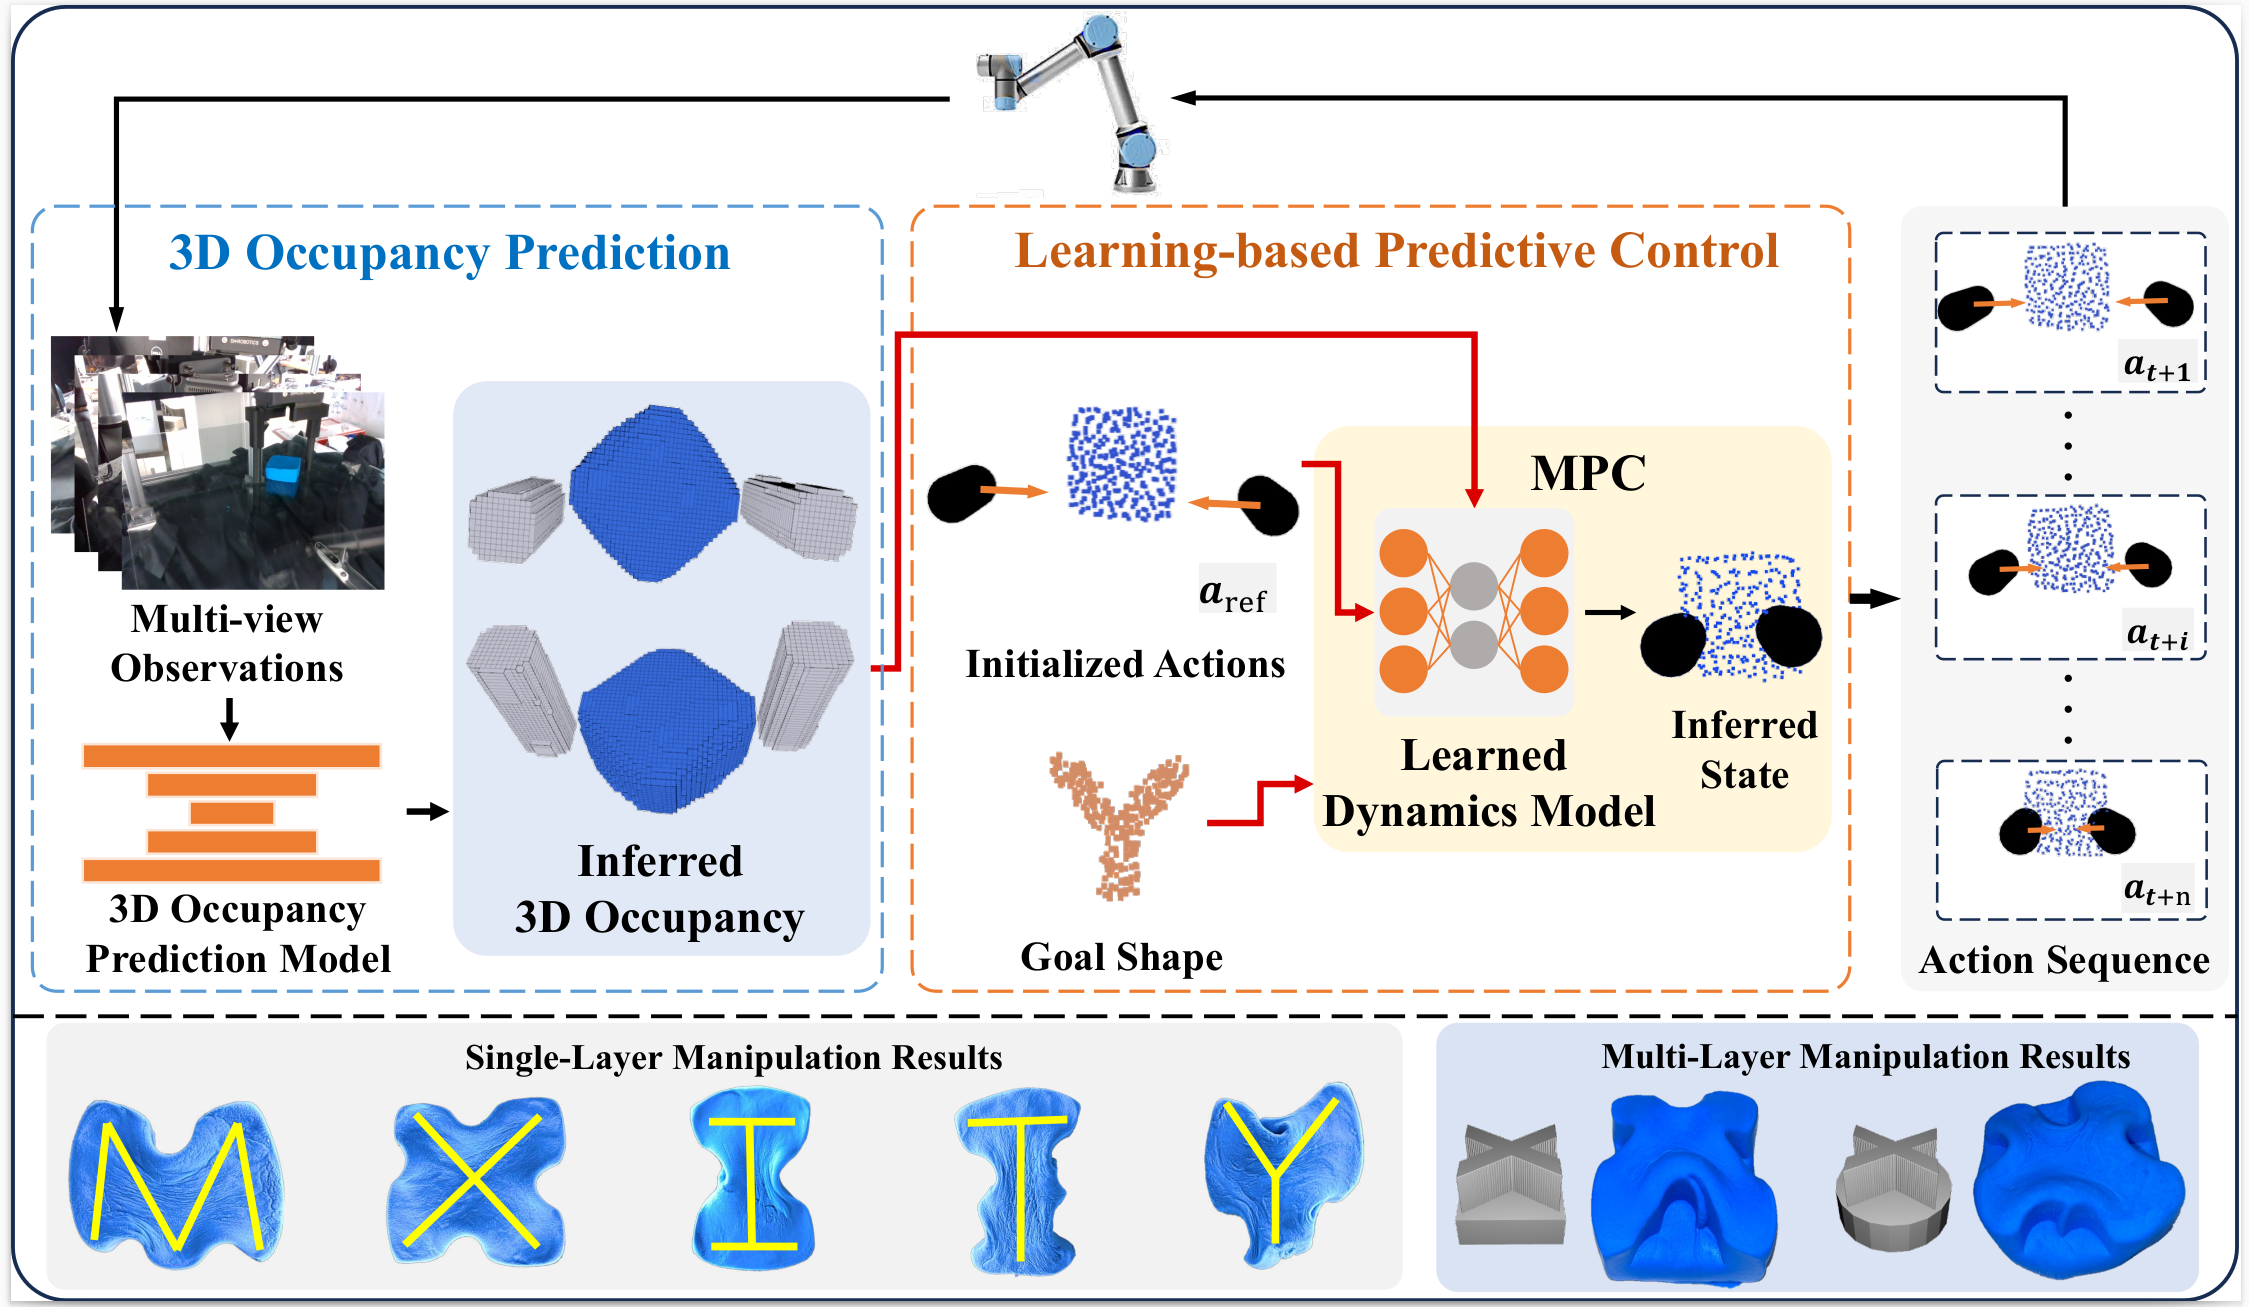
Manipulating Elasto-Plastic Objects With 3D Occupancy and Learning-Based Predictive Control
Zhen Zhang, Xiangyu Chu, Yunxi Tang, Lulu Zhao, Jing Huang, Zhongliang Jiang, K. W. Samuel Au IEEE / arXiv / IEEE Robotics and Automation Letters (RA-L) This work proposes a novel framework for elasto-plastic object manipulation, leveraging 3D occupancy to represent such objects, a learned dynamics model trained with 3D occupancy, and a learning-based predictive control algorithm. |
2024 |
|
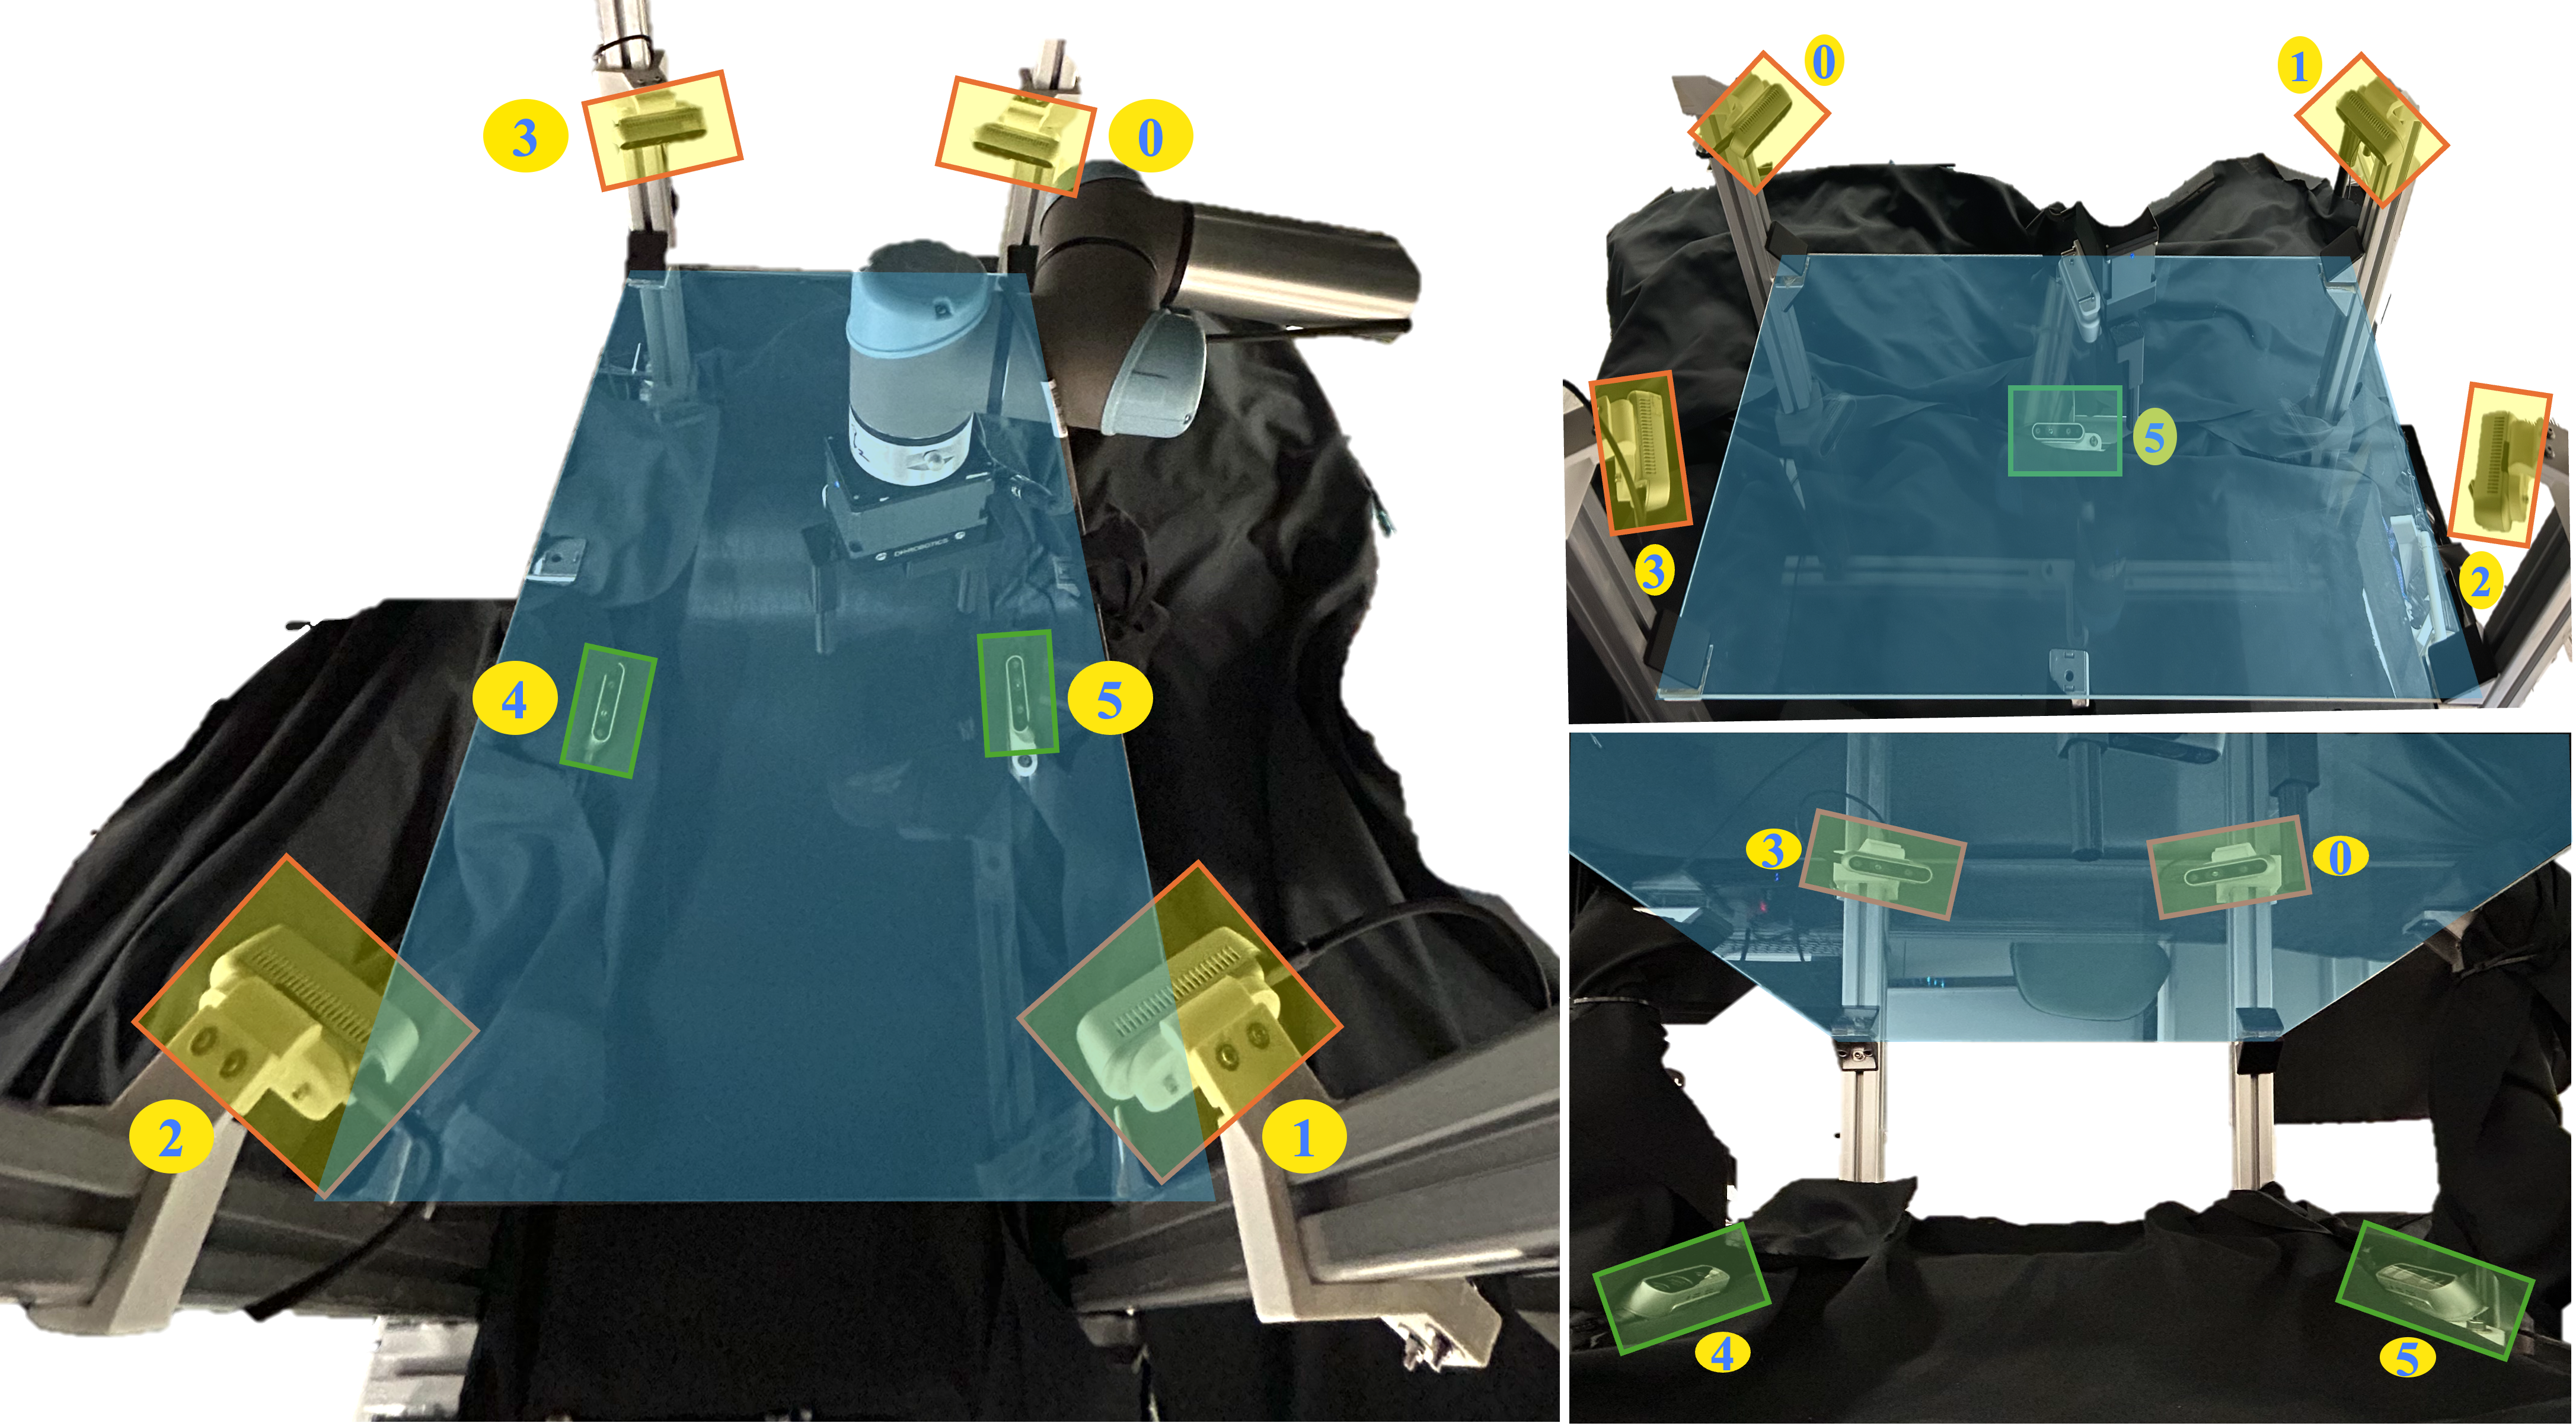
DOFS: A Real-world 3D Deformable Object Dataset with Full Spatial Information for Dynamics Model Learning
Zhen Zhang, Xiangyu Chu, Yunxi Tang, K. W. Samuel Au arXiv / CoRL 2024 Workshop LFDM This work proposes a pilot dataset of 3D deformable objects (e.g., elasto-plastic objects) with full spatial information (i.e., top, side, and bottom information) using a novel and low-cost data collection platform with a transparent operating plane. |
|
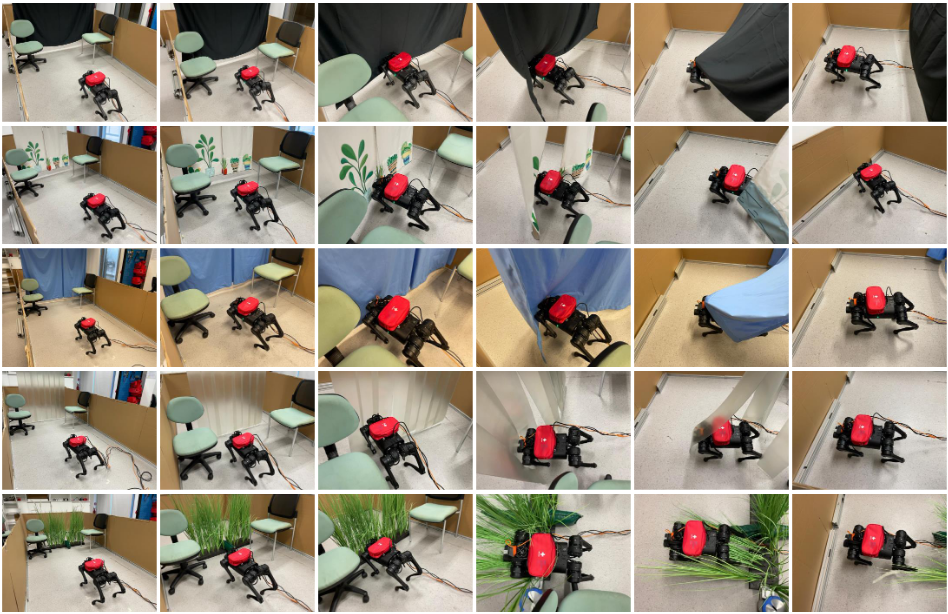
Interactive Navigation in Environments with Traversable Obstacles Using
Large Language and Vision-Language Models
Zhen Zhang, Anran Lin, Chun Wai Wong, Xiangyu Chu, Qi Dou, K. W. Samuel Au IEEE / arXiv / IEEE International Conference on Robotics and Automation (ICRA), 2024 This work proposes an interactive navigation framework using large language and vision-language models, allowing robots to navigate in environments with traversable obstacles (e.g., curtains). |
Experience |
Ph.D. Student · The Chinese University of Hong Kong
2025/01 – Present Department of Mechanical and Automation Engineering |
Research Assistant · MRC-CUHK
2023/08 – 2024/12 |
|
M.Sc. Student · The Chinese University of Hong Kong
2022/09 – 2023/06 Department of Electronic Engineering |
Algorithm Engineer · VisionNav Robotics
2022/02 – 2022/06 |
Undergraduate · Northwestern Polytechnical University
2017/09 – 2021/06 School of Marine Science and Technology |
Miscellanea |
Honors & Awards |
|
Services |
|
Beyond Research |
|
|
Thanks for the source code from Jon Barron. Last updated: |